UAV Design: Interview with Dr. Cammy Peterson
Dr. Cammy Peterson did not originally envision herself at the forefront of unmanned aerial vehicle (UAV) technology. Instead, a deeply rooted passion for problem-solving and a unique career path spanning both industry and academia propelled her into her current research. Aspiring designers and engineers alike can learn from how she navigated industry and academia, while her research and vision of the future offer unique insight into one of the most innovative spaces of the modern world.
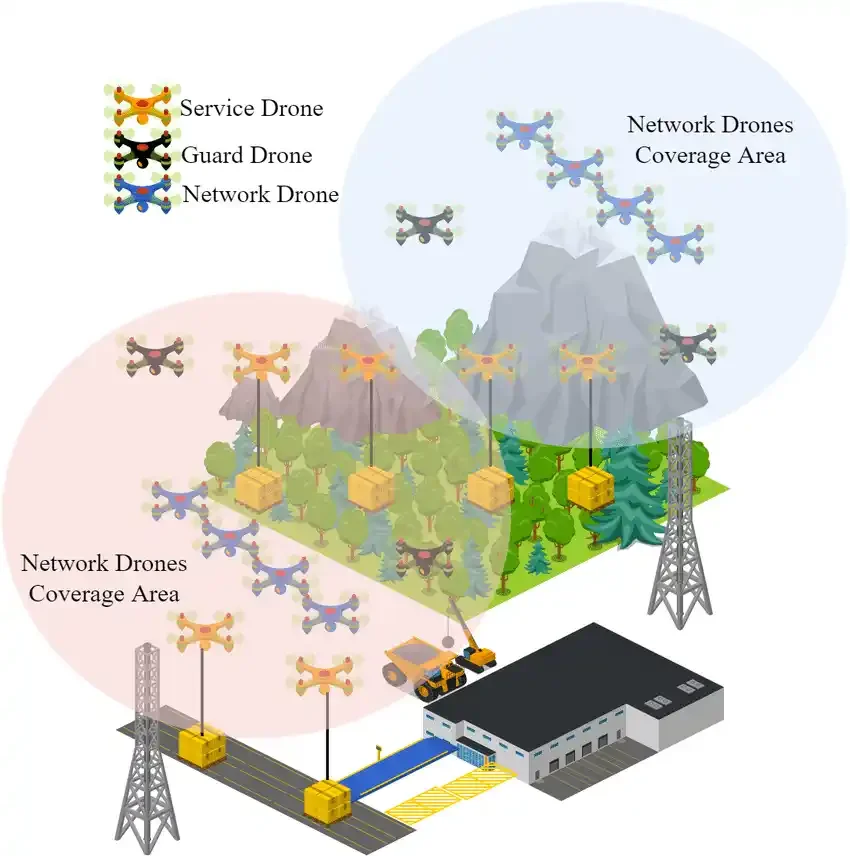
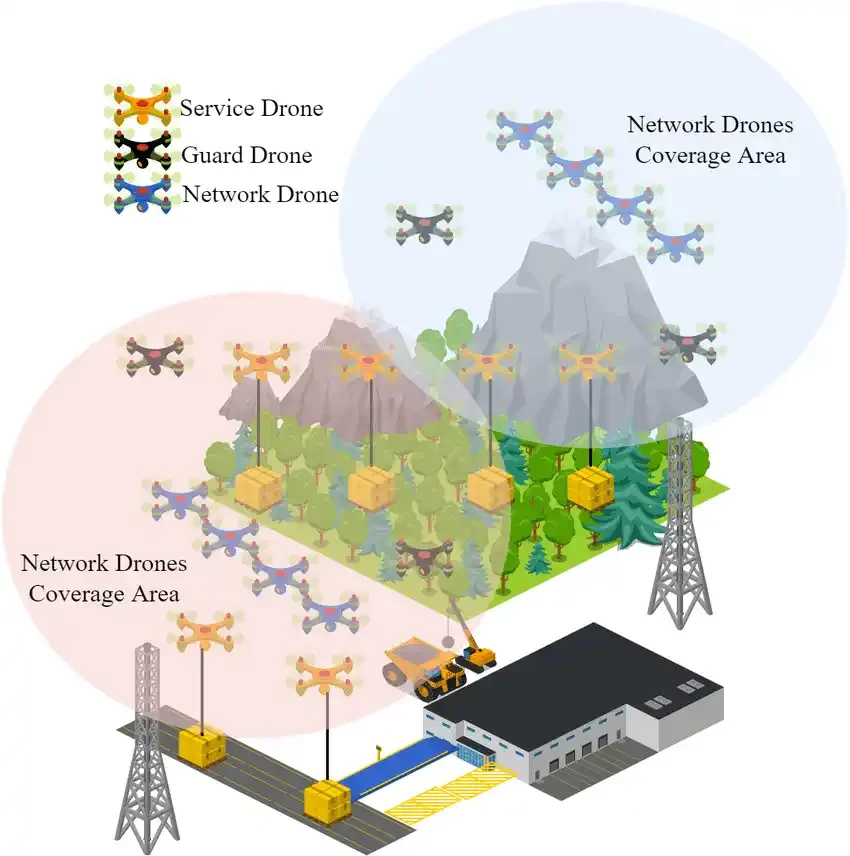
Figure 1: A diagram of potential uses for UAV swarms in civilian purposes [1].
Making Deeper Connections
After graduating with a degree in Applied Physics, Dr. Peterson lacked a concrete blueprint for her career. She took a position with a defense company—a move that helped her isolate her true interests and ultimately drew her back to academia. Working full-time, she managed to earn both her master’s degree and a PhD in aerospace engineering.
Although she expressed a love-hate relationship with physics, she felt immensely rewarded when she put in the effort to understand complex material. As a graduate student, she was frequently exposed to advanced problems that she was not sure how to solve initially, but she found it worthwhile to spend extra time learning about the topic even though she was working at the same time. She told me, “It was the challenging problems and being able to figure things out, solve puzzles, that developed deeper understanding, which made me want to make deeper connections.”
Working in the defense industry, Dr. Peterson explained, gave her an understanding of what is applicable and revealed the scope of what the customers want. She realized that academia is more high-level in its approach to development, while industry prefers what works and grounds the process. Navigating both fields simultaneously imbued her with a mindset that sees the synthesis of both approaches.
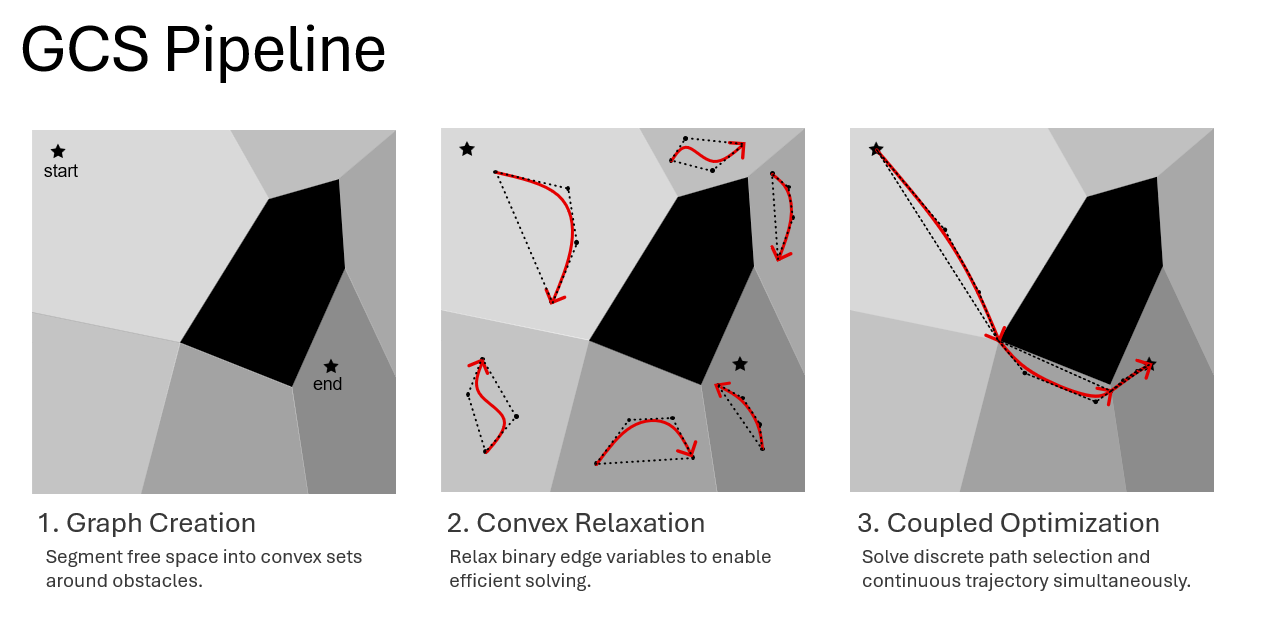
Figure 2: Graphs of Convex Sets is a unified framework (developed at MIT) that simultaneously solves discrete search and continuous refinement and guarantees global optimality [2].
Peeling Back Layers for Application
After numerous years in the private sector, Dr. Peterson eventually decided to become a professor, drawing insight from her unique background. Now, she emphasizes understanding the research that already exists, explaining to me that the techniques that we use in electrical, mechanical, and aerospace engineering have similar methods but different applications. She also thinks across disciplines, learning about computer science and even chemical engineering. “Once you get deep into a problem,” she said, “you start seeing what assumptions have been made.” Leveraging knowledge from different disciplines enables her to identify those foundational assumptions.
When it comes to UAVs, Dr. Peterson’s research revolves most around path-planning and time-based constraints. Some of her current work was built on MIT research that was designed for robots, but her team has learned how to apply it to drones. Their process begins with working out the rough algorithm or edge case for the optimization problem they are trying to solve, one that is based on many assumptions and restrictions. When she and her team have a working model, they iterate on the design to increase functionality across the modules, improving from their baseline.
Whereas her time in industry involved taking research and figuring out how to apply it, Dr. Peterson’s current work focuses on creating math theory that is proven in certain cases. “A lot of what we did in industry is taking those ideas and asking how we make that work in the real world,” she explained. “We want to make it robust and peel back a layer to make it more applicable.” When the government saw promise in the prototypes, the products were bid out to a large defense contractor.
As an avid hiker and nature-lover, Dr. Peterson has also learned that nature is a living demonstration of engineering principles. Feedback loops are important in control theory, but they also pervade nature, such as in human bodies. Thinking of humans as the controlling system, one can see robotic systems that are at work to keep them on the path. Engineers like Dr. Peterson can ask themselves how to design a robot and an algorithm to recreate that functionality in a sophisticated way.
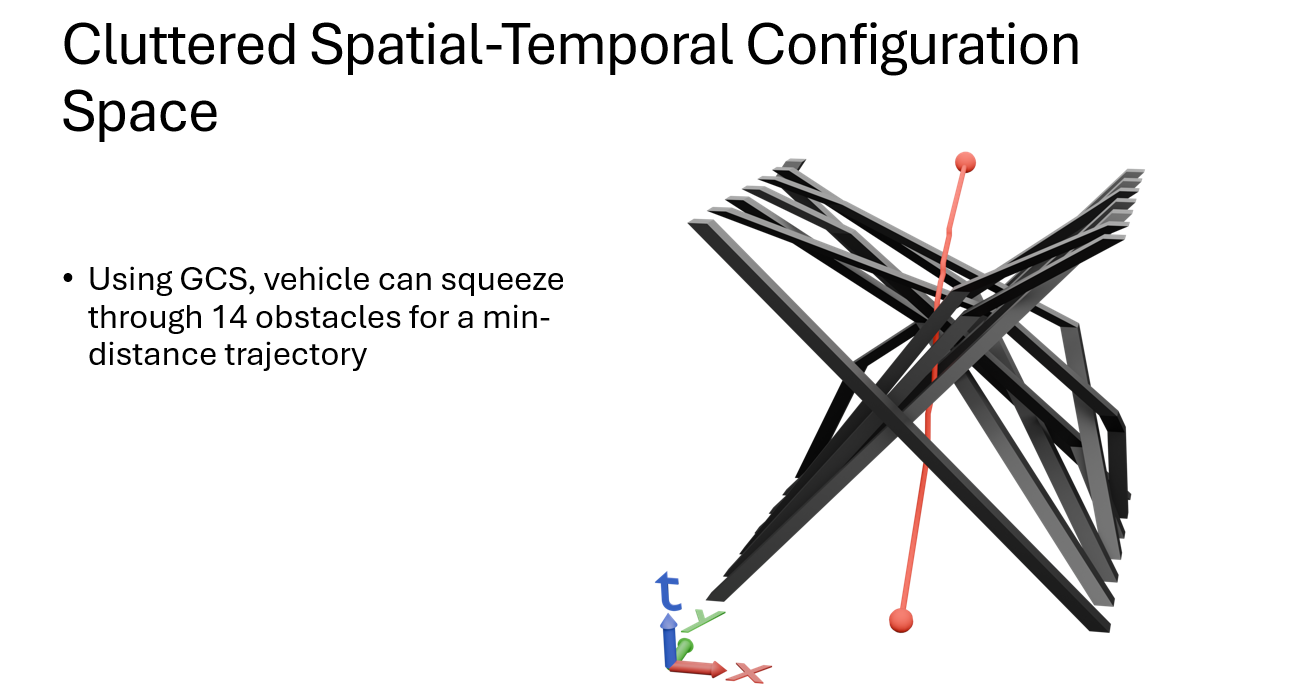
Figure 3: A 3D diagram illustration of a path-solving algorithm developed by Dr. Peterson [2].
Capability for Extreme Environments
Dr. Peterson is excited to see how UAV technology expands in the years ahead, especially with the advent of AI. From her background in defense, Dr. Peterson anticipates seeing breakthroughs in multi-agent drone swarms that can make decentralized, individual decisions. Though drone swarms currently do exist in smaller numbers, computing power requirements do not scale linearly, so important research must be done for larger swarms of hundreds of drones that will need to be able to make decisions as a group without having to overload processors. Models are unveiling emergent behaviors of how a group behaves, but progress is needed to shape how the emergent behaviors work and get drones to work together.
Another promising avenue is that of air taxis. Although the legalization process has been slowed because of legitimate safety concerns and challenges with seeing obstacles because of sensor limits, there are countless commercial applications. When they become safe enough, drones will also be trained to inspect dangerous or difficult-to-reach areas, monitor living things like algae or fauna, check for avalanches, explore mining operations, replace heavy-lift cranes, and even enable autonomous cargo flights. Dr. Peterson said, “I would like to see this technology used where we can take humans out of dangerous situations and make it safer for them. And that includes - and we’ve already seen it - quadcopters being sent to Mars. There’s capability out there for these extreme environments.” Safety and operation parameters cannot be guaranteed immediately, but AI is expediting the process, and new robots and drones with different dynamics will be able to roll out into the field quickly.
Opportunities in engineering are almost endless, but a combination of industry and academic experience yields a special perspective into design. Dr. Peterson combines her knowledge of consumer-oriented design with the leeway inherent in research to devise creative solutions for real-world problems. Although she may not have planned to be a leader in emerging drone technology, her dedication to learning has taken her there.
References
[1] Aydin, Yucel, et al. “Authentication and Handover Challenges and Methods for Drone Swarms.” ResearchGate, Jan. 2022, https://www.researchgate.net/publication/357836252
[2] Osburn, Matthew D., et al. "Systematic Constraint Formulation and Collision-Free Trajectory Planning Using Space-Time Graphs of Convex Sets." arXiv, 24 Sept. 2025, https://doi.org/10.48550/arXiv.2508.10203.
To cite this article:
Conover, Dylan. “UAV Design: Interview with Dr. Cammy Peterson.” The BYU Design Review, 10 Aug 2026, https://www.designreview.byu.edu/collections/uav-design-interview-with-dr-cammy-peterson.